PaperarXiv:2611.10137
A Unified Inertial Encoder for Human and Humanoid Motion
arXiv preprint (cs.RO)
 (opens in a new tab)
Chen, Yutian et al., "A Unified Inertial Encoder for Human and Humanoid Motion", arXiv:2611.10137, CC BY 4.0
TL;DR
Amazon FAR / Berkeley / Stanford / CMU inertial encoder trained on human motion with synthesized IMU streams and language labels plus retargeted humanoid motion. Lowest velocity error on all five datasets tested (0.099 m/s on a real Unitree G1, zero-shot) and motion-text retrieval. Apache-2.0 code and a 55.6M-parameter checkpoint on HF (weights licence 'other').
Abstract
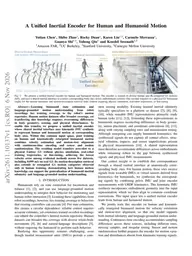
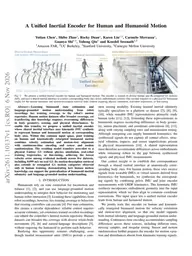
Learning humanoid state estimation and language-grounded motion understanding from robot recordings ties training coverage to the robot's motion repertoire. Human motion datasets offer broader coverage, yet transferring this knowledge requires overcoming differences in body geometry, sensing, and physical disturbances. To enable this transfer, we propose a unified inertial encoder whose shared inertial interface uses kinematic IMU synthesis to represent human and humanoid motion at corresponding body sites. Within this common input space, joint training on human and kinematically retargeted humanoid motion combines velocity estimation and motion–text alignment with continuous-time encoding and sensor and motion randomization. The resulting model transfers zero-shot to a physical Unitree G1 without physics simulation, real-robot training trajectories, or fine-tuning, achieving the lowest velocity error among evaluated methods across five datasets, including 0.099m/s on real G1. Its motion-description retrieval also extends to retargeted G1 motion categories observed only in human training, demonstrating how human motion knowledge can support the generalization of humanoid inertial odometry and language-grounded motion understanding.
Verbatim from arXiv (opens in a new tab) · arXiv metadata (abstracts are released under CC0)
Results on ChatPPG leaderboards
All leaderboardsNo results from this paper on ChatPPG leaderboards yet. Browse the leaderboards.
Tasks & signals
Signals
Keywords
Models
How it works
Cite this paper
Chen, Y., Zhao, S., Duan, R., Liu, K., Sferrazza, C., Shi, G., Qiu, Y., & Sreenath, K. (2026). A Unified Inertial Encoder for Human and Humanoid Motion. arXiv preprint. https://arxiv.org/abs/2611.10137
Chen, Yutian, Shibo Zhao, Rocky Duan, Karen Liu, Carmelo Sferrazza, Guanya Shi, Yuheng Qiu, and Koushil Sreenath. 2026. "A Unified Inertial Encoder for Human and Humanoid Motion." arXiv preprint. https://arxiv.org/abs/2611.10137.
Chen, Y., Zhao, S., Duan, R., Liu, K., Sferrazza, C., Shi, G., Qiu, Y. and Sreenath, K. (2026) 'A Unified Inertial Encoder for Human and Humanoid Motion', arXiv preprint. Available at: https://arxiv.org/abs/2611.10137
Chen, Yutian, et al. "A Unified Inertial Encoder for Human and Humanoid Motion." arXiv preprint, 2026. https://arxiv.org/abs/2611.10137.
Y. Chen et al., "A Unified Inertial Encoder for Human and Humanoid Motion," arXiv preprint, 2026, [Online]. Available: https://arxiv.org/abs/2611.10137.
@misc{chen2026unified,
  title         = {{A Unified Inertial Encoder for Human and Humanoid Motion}},
  author        = {Chen, Yutian and Zhao, Shibo and Duan, Rocky and Liu, Karen and Sferrazza, Carmelo and Shi, Guanya and Qiu, Yuheng and Sreenath, Koushil},
  year          = {2026},
  howpublished  = {arXiv preprint},
  eprint        = {2611.10137},
  archivePrefix = {arXiv}
}Added to the ChatPPG research hub